ROBOT x Manufacturing
Large scale surface patterning of micro-structured functional surfaces using a cohort of robots.
Micro-structured surfaces possess useful properties such as friction modification, anti-fouling, and hydrophobicity. However, manufacturing these surfaces in an affordable, scalable, and efficient manner remains challenging. Standard coverage methods for surface patterning require precise placement of micro-scale features over meter-scale surfaces with expensive tooling for support. These works address the scalability challenge in surface patterning through a team of mobile robots. We’ve demonstrated that credit-card-sized “minions” can generate micro-scale divots using a modulated tool tip to pattern meter-scale workpieces, or use a sanding actuator to reduce surface roughness. We show that an Ergodic Control architecture with a target based on feature density can specify surface coverage, eliminating the dependence on individual indentation locations. Our robots automatically plan their trajectories to produce high-fidelity surface patterns and achieve automatic coverage based on sophisticated target images. Robots can either work independently, or as a team with shared or cascaded trajectory histories to divide tasks. We’ve validated robot performance by controlling the coefficient of friction in a submerged lubrication regime by adjusting the density of indentations, and by producing various recognizable images including the Eiffel Tower and Arc de Triomphe. These works show the potential for compact robots to perform scalable manufacturing of functional surfaces enabled by density-based target specifications (Taylor et al., 2024; Landis et al., 2025; Taylor et al., 2026; Landis et al., 2026).
(in collaboration with Prof. Todd Murphey)

References
2026
-
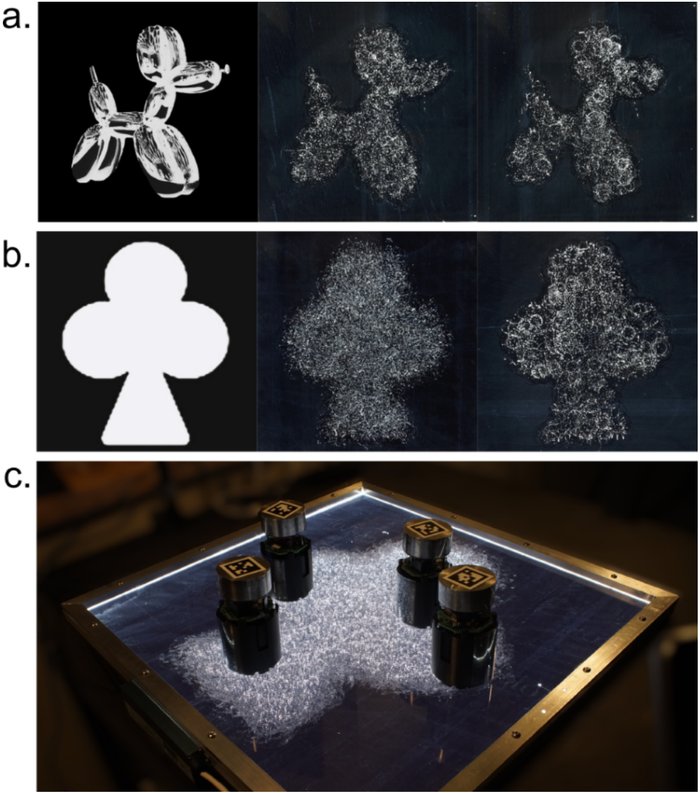 arXiv preprint arXiv:2603.18260, Oct 2026
-
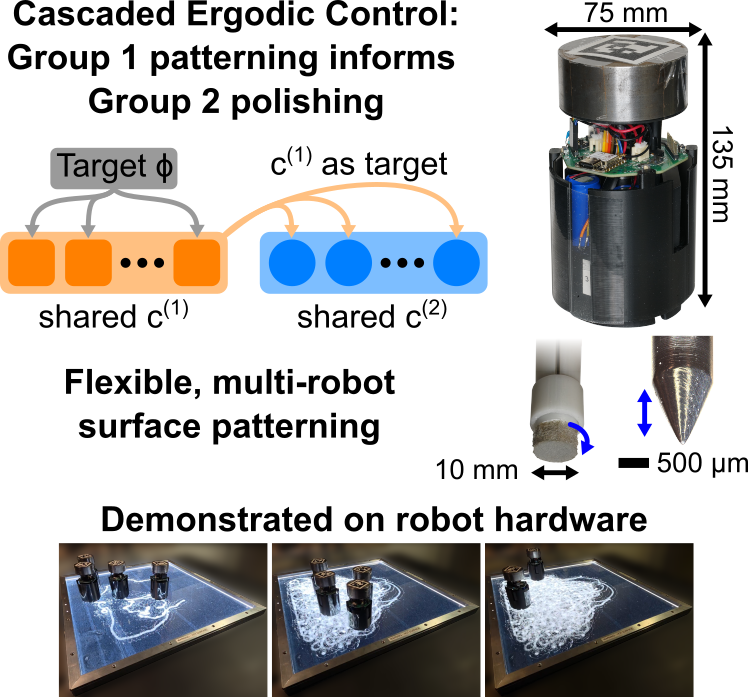 Journal of Manufacturing Systems, Oct 2026


2025
-
 CIRP Annals, Oct 2025

2024
-
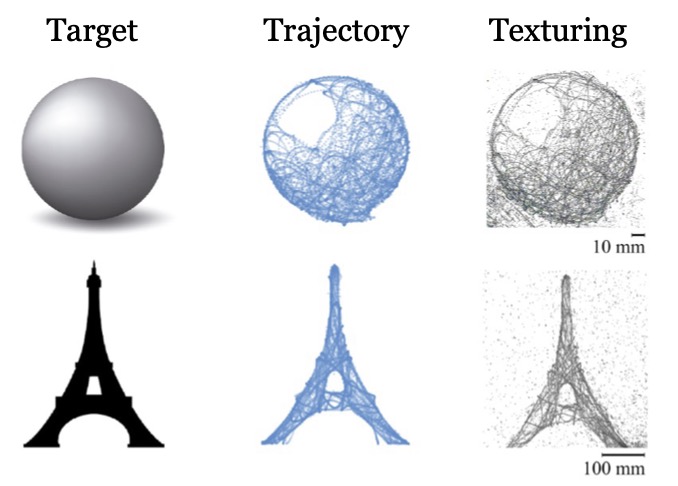 In 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , Oct 2024
